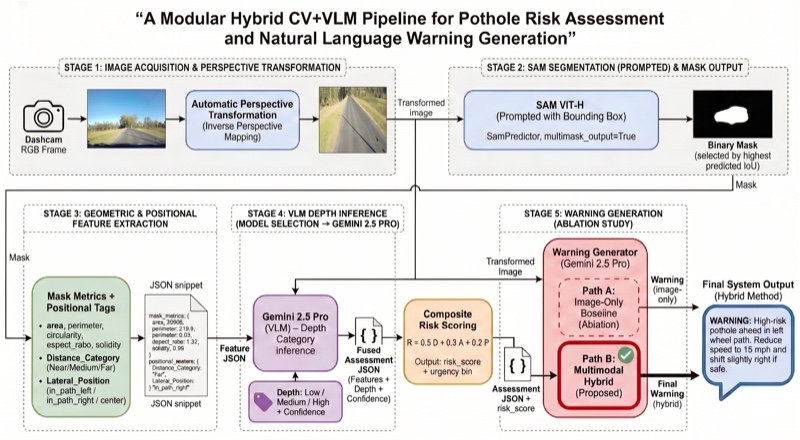
Pothole Risk Assessment with Geometrically Grounded Vision Language Models
Combines geometric measurements from dashcam images with vision-language models to score pothole risk and generate warnings for offline assessment.
Robotics Engineer & Researcher
I work on robot policy post-training and evaluation at Midcentury. My work focuses on how egocentric human demonstrations can help robots generalize to new settings.
My graduate research at the University of Michigan’s BIMI Laboratory focuses on vision-based navigation for mobile robots. I earned my bachelor’s in mechatronics engineering at the University of Jordan.
[01]
[02]
Combines geometric measurements from dashcam images with vision-language models to score pothole risk and generate warnings for offline assessment.

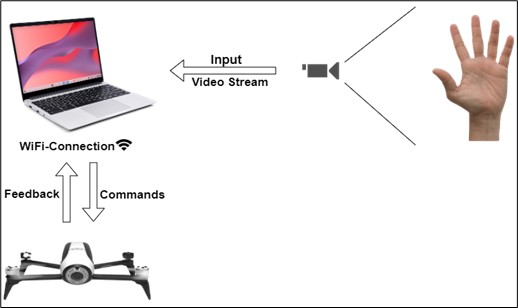
Maps camera-detected hand gestures to drone flight commands in real time and tests the system at different altitudes and lighting levels.


[03]
Midcentury
Jun 2026 – Present

Bio-Inspired Machine Intelligence (BIMI) Laboratory
Jan 2025 - Present
Visit Lab
BeyondAI
Mar 2023 – Present
Previously Data Scientist Intern, Jun 2022 – Mar 2023
Company
Woven by Toyota
Jan 2026 – Jun 2026
Company
Bosch Sensortec
Summer 2023
Company[04]
A modular map of the stack I use to ship robotics systems from sensor wiring to deployed autonomy.
Sensor Ingestion → Perception → Planning/Control → Edge Deployment → Monitoring
[05]
Skills: GPU, Cloud Computing, HPC, Data Centers, Parallel Computing.
Show CredentialGrade: Excellence. Focused on robotics, autonomous flight, and control systems.
Show CredentialQuality engineering methods for process optimization and structured improvement.